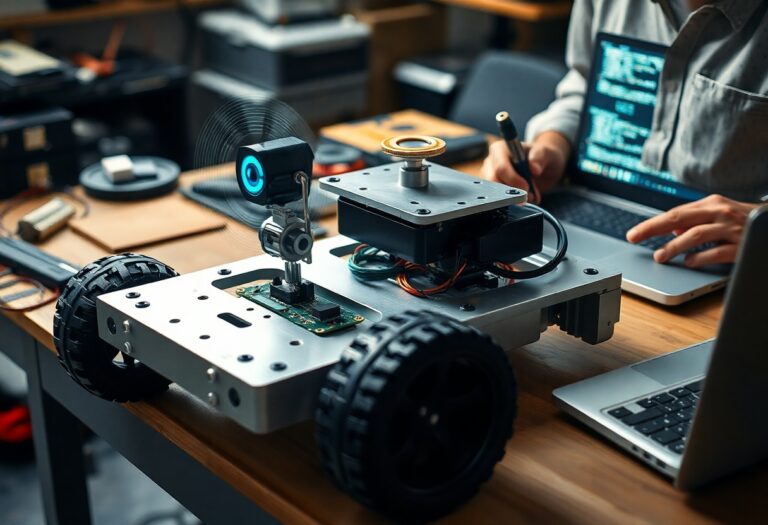
Constructing a Robot for Autonomous Navigation
Over this concise guide, you will learn sensor selection, control design, perception integration, and testing methods to build an autonomous robot that reliably maps and avoids obstacles. Hardware Selection and Mechanical Design Select components that match sensor payload, computation, and mounting constraints so you can swap parts during testing and iterate quickly. Chassis Configuration and…